Cobots: Deploying Collaborative Robots Alongside People
A cobot pays off with changing tasks and small to medium volumes once it runs several hours a day, because after a risk assessment it can often work beside employees without a safety fence. Payback is decided by operating hours and the working hours actually released, as well as by the cost of gripper and integration, which come on top of the price of the robot arm. This article sets out the calculation and the safety logic of the standard and describes how a mid-sized manufacturer introduces its first cobot.
The article is written for managing directors and plant managers who must decide whether a collaborative robot is an option for their production or logistics. It covers the technology as far as it shapes the decision, and the economics as concretely as is possible without knowing your figures. The safety of an installation is governed by standards and statutory requirements that specialists assess case by case: this article provides an overview and does not constitute legal advice.
What is a cobot, and how does it differ from an industrial robot?
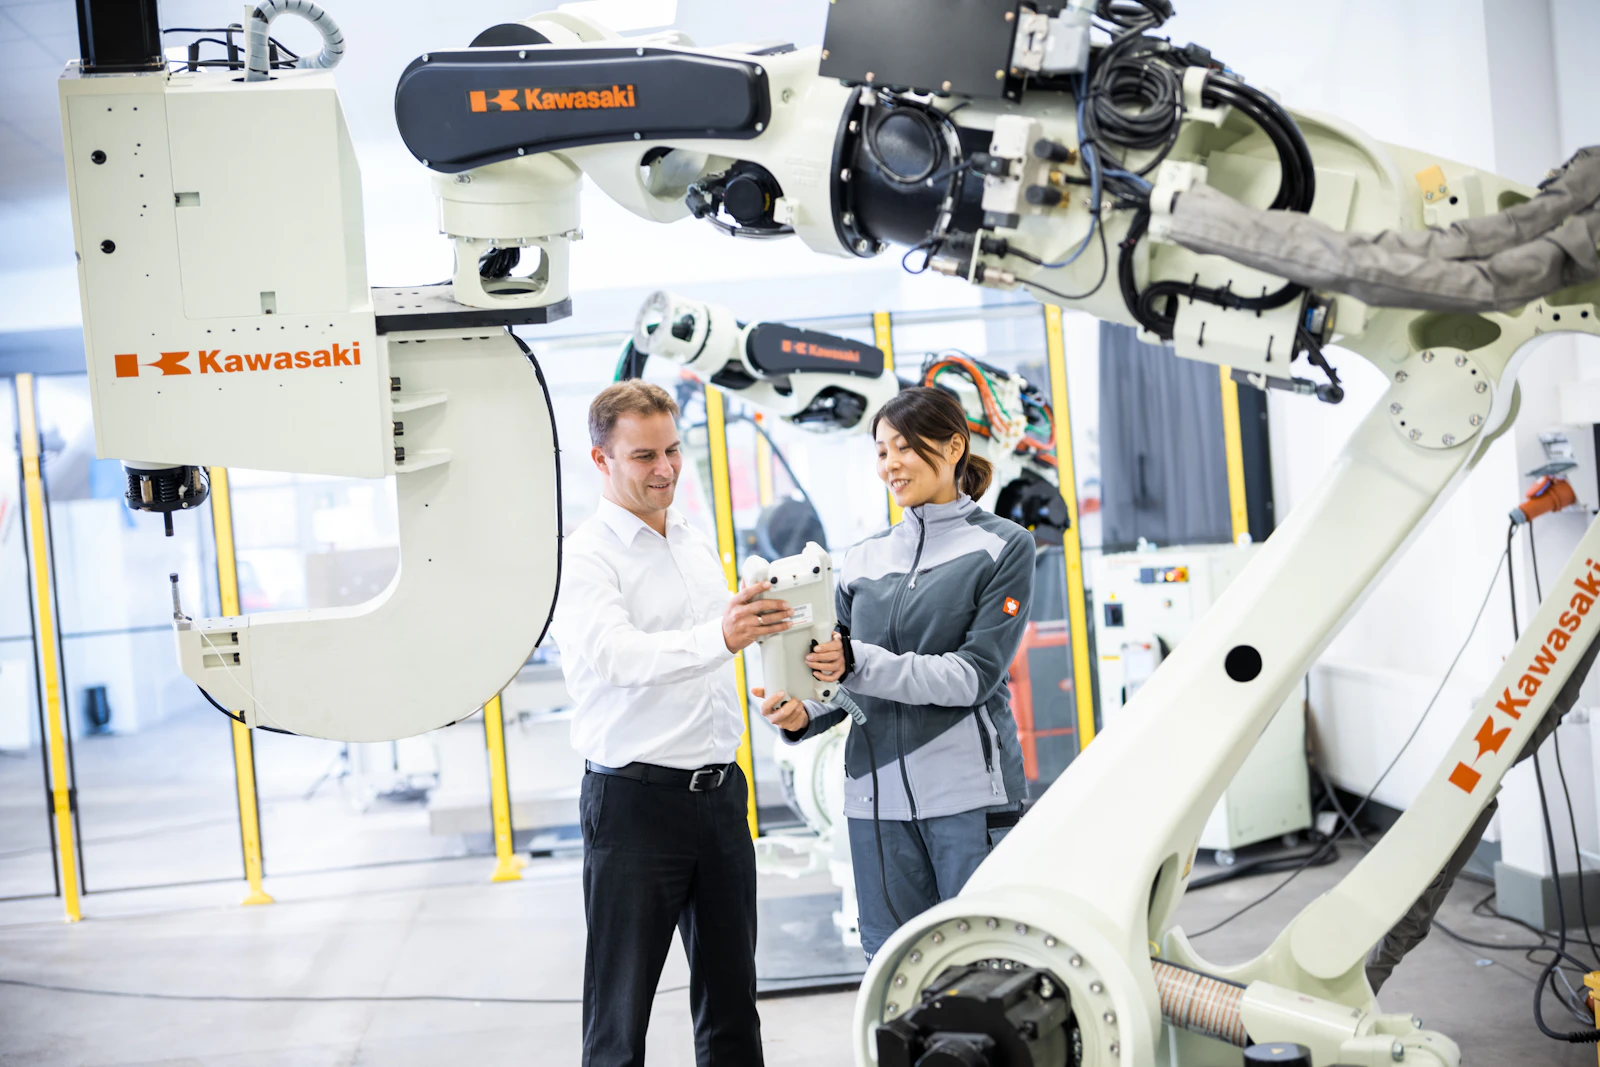
A cobot is a robot designed to work in the same workspace as people. Conventional industrial robots work fast and with great force and, for safety reasons, stand behind fences or light curtains. Cobots limit force and speed and stop on contact, so that a fence can be omitted in many applications. The consequence is a smaller footprint and simpler commissioning. The price is lower speed and smaller payloads.
Their importance is growing. According to the International Federation of Robotics in its World Robotics 2023 report, around 553,000 industrial robots were installed worldwide in 2022, roughly one in ten of them as a collaborative robot. For mid-sized firms this matters because cobots lower the threshold to automation: they need less floor space and can be set up for new tasks with limited programming effort. An overview of where robots are economic in mid-sized companies today is given in the article on robotics in the Mittelstand.
Which four forms of collaboration does the standard recognise?
The technical specification ISO/TS 15066 of 2016 describes four operating modes for collaboration between human and robot. It supplements ISO 10218-1 and ISO 10218-2 of 2011 on the safety of industrial robots and robot systems. The four forms can be used singly or in combination, and the choice determines how fast the robot may work.
Power and force limiting is the mode that many people associate with a cobot. It lowers the cycle time noticeably compared with a fenced robot. Gripper and workpiece are part of the risk assessment: a cobot carrying a sharp tool creates a hazard even with limited force. The risk assessment therefore applies to the whole application and is prepared by safety specialists before commissioning.
When does a cobot pay off, and when a conventional robot?
A cobot pays off when tasks change often and volumes are small to medium. That applies above all when the workplace involves a person. A conventional industrial robot pays off at high volumes and fast cycle times, where a fence is no obstacle. Manual work stays economic when tasks occur rarely.
What does a cobot installation cost, and when does it pay back?
The cost of a cobot installation consists of the robot arm plus the cost of gripper, integration and running operation, so the arm is only one part of the investment. There are no independent price lists for the total investment, because it varies with the task and the connection to machines. Economics can therefore be calculated reliably only with your own figures. Payback follows from the investment divided by the monthly net benefit.
Two assumptions deserve attention. The calculation counts released working hours as a benefit only if employees use that time for other tasks, for example for orders that previously went undone. Second, it assumes that the process runs stably before automation: a cobot that has to handle inaccurate parts or fluctuating deliveries stands idle more often than planned. How teams and business units guide an investment together up to acceptance is described in the article on the definition of done.
How do you introduce cobots in four steps?
You introduce cobots by selecting the task, calculating the business case, building a pilot station with the employees and assigning responsibility for operation from the start. Each step has a result that the executive team can check.
- Select the task: suitable activities strain the body and repeat themselves. The result is a list of three to five candidates with volume and operating hours.
- Calculate the business case: for the most promising task you calculate investment and payback with real figures from production. The business units confirm the assumptions.
- Build the pilot station: a system integrator plans and installs the application, including the risk assessment. The employees who will later work with the cobot take part in the design. The criterion for the end of the stage is proof in the real process with real parts.
- Take responsibility for operation: before the first day it is settled who clears faults and who changes programs. After 90 days the plant management compares utilisation and downtime with the business case.
Why do cobot projects fail?
In practice, cobot projects fail above all on the organisation around the robot. One frequent reason is an unclear owner: the robot belongs neither to production nor to maintenance, and nobody looks after program changes. A second is a business case based on data sheet values instead of measured cycle times. A third is the acceptance of employees, who experience the robot as a threat to their jobs when nobody explains the intention. A fourth is the number of parts: anyone who wants to handle too many variants on one station spends the time on changeovers. How a robust plan emerges from the pressure to invest in automation is shown in the article on AI activism.
Cobots with Niehues Consulting
Niehues Consulting is a Düsseldorf consultancy for AI management and organisation design from the delivery perspective. Founder Marin Niehues builds organisations that deliver, in projects ranging from VC-funded scale-ups to DAX 40 groups and in more than 20 countries on six continents. For a cobot deployment he works on the business case and the introduction: on the selection of the task and on the roles in operation. The robot itself is planned and installed by a system integrator.
The approach follows the Niehues Delivery Model with its three phases. Three of its review questions matter most for cobots: Is the business case confirmed with real values? Who is responsible for operation from day one? Which metric shows after 90 days that the solution is landing? The entry point is a free initial consultation of 30 minutes, which you can arrange via contact.
Frequently asked questions
What is a cobot?
A cobot is a collaborative robot built to work in the same space as people. It limits force and speed and stops on contact. Many applications therefore manage without a safety fence, provided the risk assessment permits it.
How much does a cobot cost?
The cost is made up of robot arm, gripper, integration, training and running operation. The worked example in this article assumes a total investment of 75,000 euros, a value for illustration and not a market figure. Reliable figures emerge from a business case with your own tasks and operating hours and from quotations by system integrators.
What is the payback period of a cobot?
Payback is the investment divided by the monthly net benefit. In our worked example it is 26 months for one shift and twelve months for two shifts. Operating hours and the working time that is actually redeployed determine the result.
Does a cobot need a safety fence?
Whether a cobot can work without a safety fence is decided by the risk assessment of the whole application. Gripper and workpiece are part of it. The cobot alone does not make an installation safe.
What does ISO/TS 15066 cover?
ISO/TS 15066 describes four operating modes of human-robot collaboration: safety-rated monitored stop, hand guiding, speed and separation monitoring, and power and force limiting. It also contains limit values for contact forces on body regions. It supplements ISO 10218-1 and -2.
Which tasks suit cobots?
Cobots suit palletising and inspection tasks with clearly defined parts. They fit small and medium volumes with frequent task changes. For fast cycle times and heavy loads, conventional industrial robots are the better choice.
Do cobots replace jobs?
Cobots take over individual strenuous or repetitive activities and relieve employees there. A gain arises when the time freed is used for other tasks. Early involvement of employees and a clear explanation of the intention are decisive for acceptance.
Who introduces a cobot in a company?
Planning and installation are usually carried out by a system integrator. The business case and the steering of the project lie with the company and can be supported by consulting. Before the first day of operation, an owner for faults and program changes must be named.
Let’s talk about your initiative.
In 30 minutes we clarify where your organisation stands and which step will pay off most now.
Book a consultation30 minutes · free of charge · no obligation